Welcome to Zijian's Academic CV !
Welcome to Zijian's Academic CV !
Home
Experience
Projects
Publications & Patent
Honors
Contact
Light
Dark
Automatic
Optimization-Base Motion Control
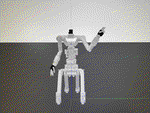
Motion Control for Wheel-legged Humanoid Robots
By planning and controlling the Cartesian position of the humanoid robot’s upper body, I enabled the robot to perform actions such as wiping a table.
Oct 10, 2024
Youtube
Motion control with Unitree Go1 Max
I personal purchased a Unitree Go1 Max(not EDU) robot and have done some locomotion tests.
Oct 1, 2024
Compliance Control for Multi-Arm Space Robot crawling
Proposed a whole-body compliant motion control strategy to ensure stable contact between the end-effector gripper and the space truss.
May 1, 2024
Compliance Control for Quadruped wheel-legged robot
We are attempting to perform a stair climbing motion control test for a wheel-legged quadruped robot.
Jun 1, 2023
Dual-Arm Space Robot Testbed
We proposed a weighted-priority-based switching model predictive control (SMPC) method to ensure continuous transitions between different states for efficient sequential operations.
May 1, 2023
Compliance control with Franka Emika Panda Robot
Admittance control tests were performed.
Jan 1, 2023
Cite
×