Gaussian-Mixture-Model-Based Model Predictive Control for Space Robot in Task-space
Abstract
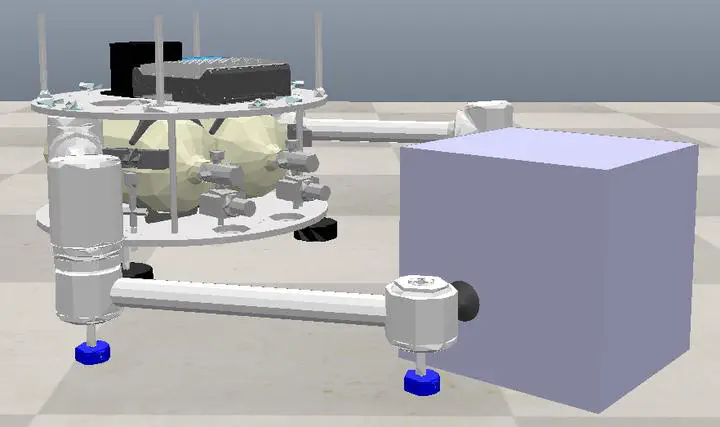
The Gaussian-mixture-model-based model predictive controller is proposed for the precise operation requirement and task-space control problem of space robots. Based on the nominal model, the Gaussian mixture model is utilized to analyze and compensate the model uncertainties accurately and efficiently, which are caused by the joint friction, measurement error, etc. Then, considering the physical constraints, such as joint limitations and input saturations, the nonlinear model predictive control method incorporated with the augmented model is proposed to realize the direct and accurate tracking for both the robot base and end-effectors pose. Besides, the thrust allocation algorithm is presented for the thruster’s redundant configuration. Finally, the effectiveness of the proposed method is verified by the simulation results.