Compliance Control for Quadruped wheel-legged robot
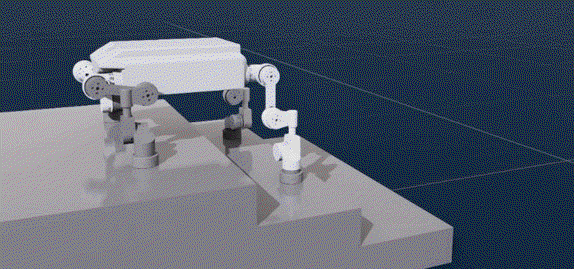 Photo by rawpixel on Unsplash
This robot was designed by my team and me. We have already created a URDF model of the robot and are testing it in Isaac Sim simulation.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.