Compliance Control for Multi-Arm Space Robot crawling
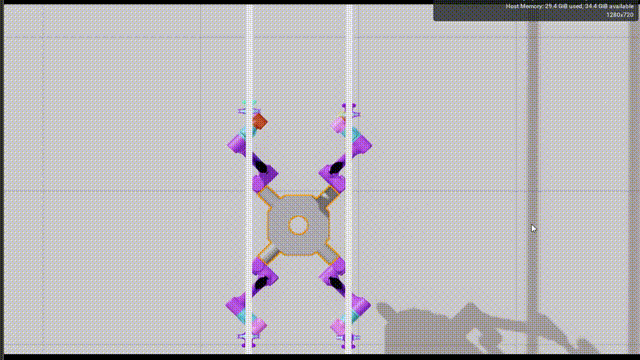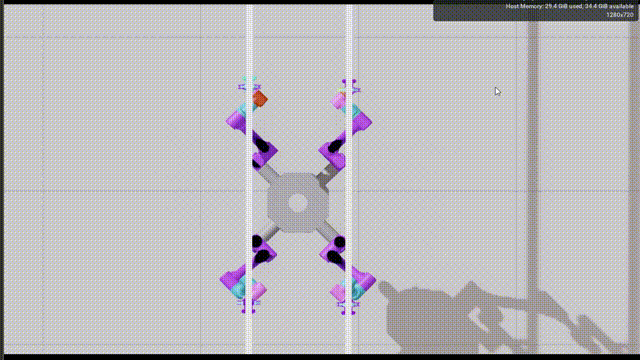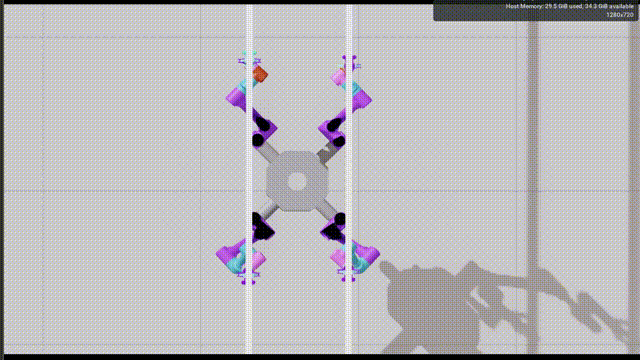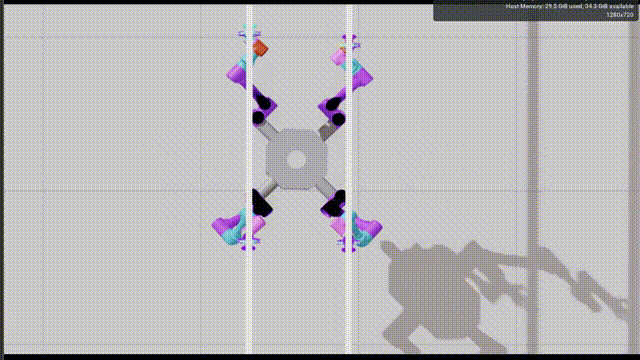 Photo by rawpixel on Unsplash
I addressed the issue of closed-chain force conflicts during the space truss crawling of a multi-arm robot. I proposed a whole-body compliant control strategy, analyzing the force mapping between interactive forces and the base, establishing a compliance model between the floating base and the end-effector Cartesian space.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.