Dual-Arm Space Robot Testbed
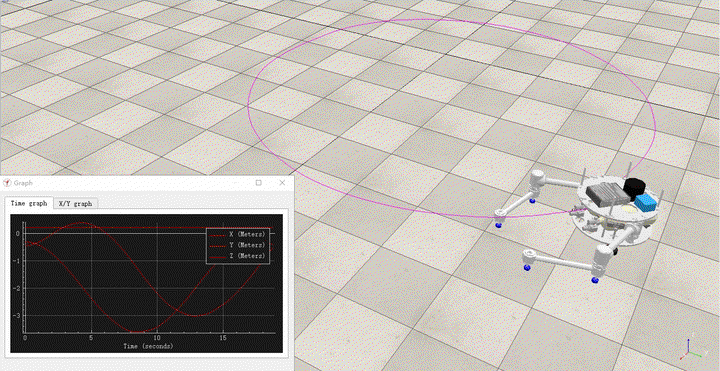 Photo by rawpixel on Unsplash
I analyzed the dynamics of a floating base for a dual-arm mobile robot based on air bearings, calculating the torque distribution of thrusters and employing MPC optimization to equate energy consumption to PWM output for the solenoid valves, calculating the optimal output force/torque.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.