Modular Bionic Snake Robot
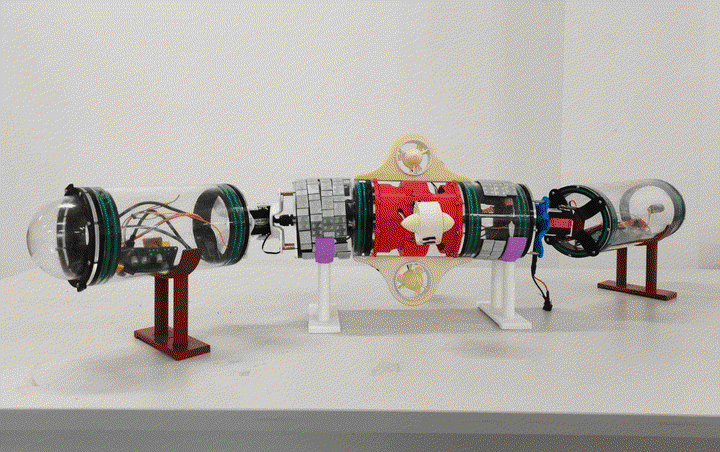 Photo by rawpixel on Unsplash
I used stm32f103 chips, custom PCB driver boards, high torque servos and enclosed water tanks to design a multi-joint ROV modular bionic snake underwater robot, which has higher flexibility through vector thrusters.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.