Amphibious Bionic Robot
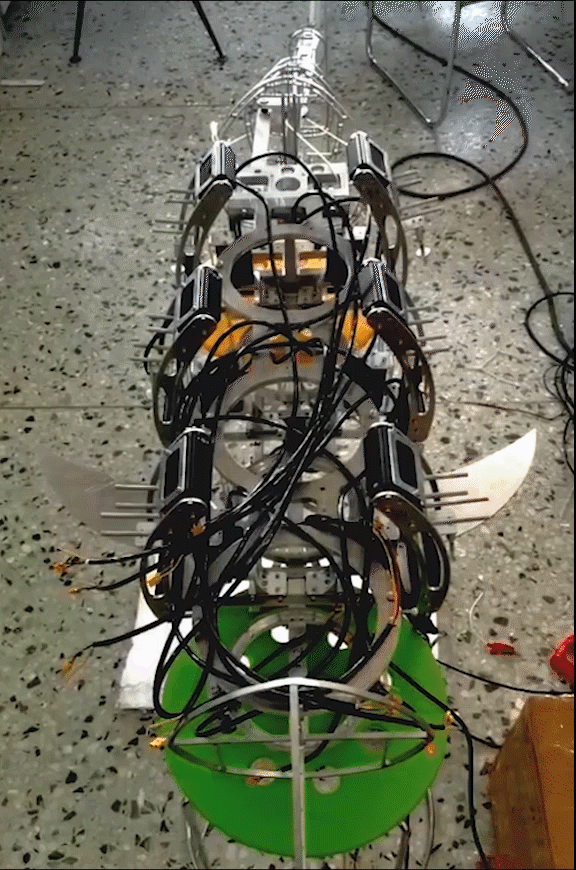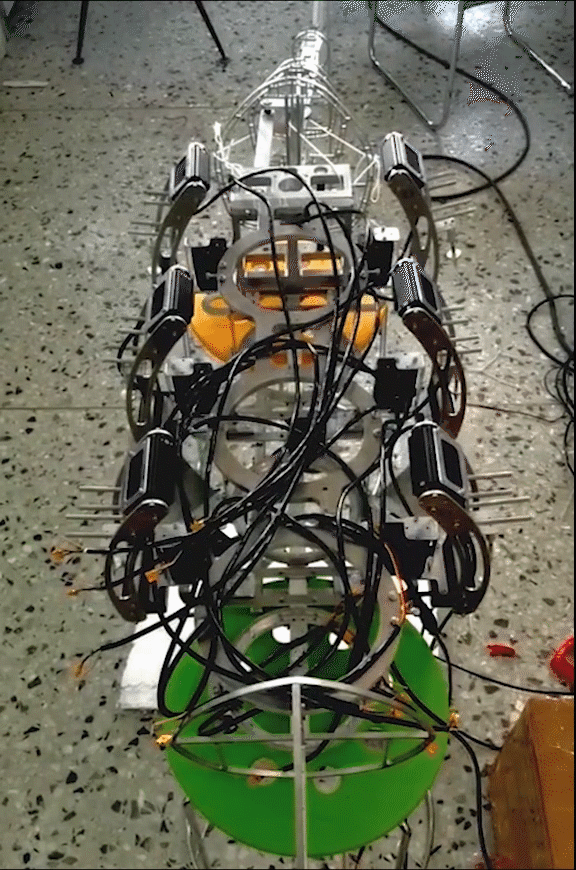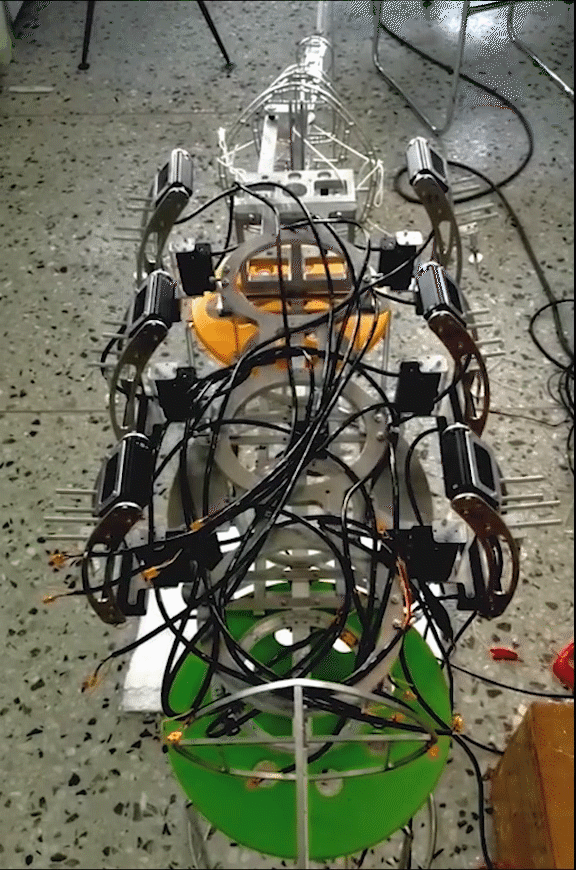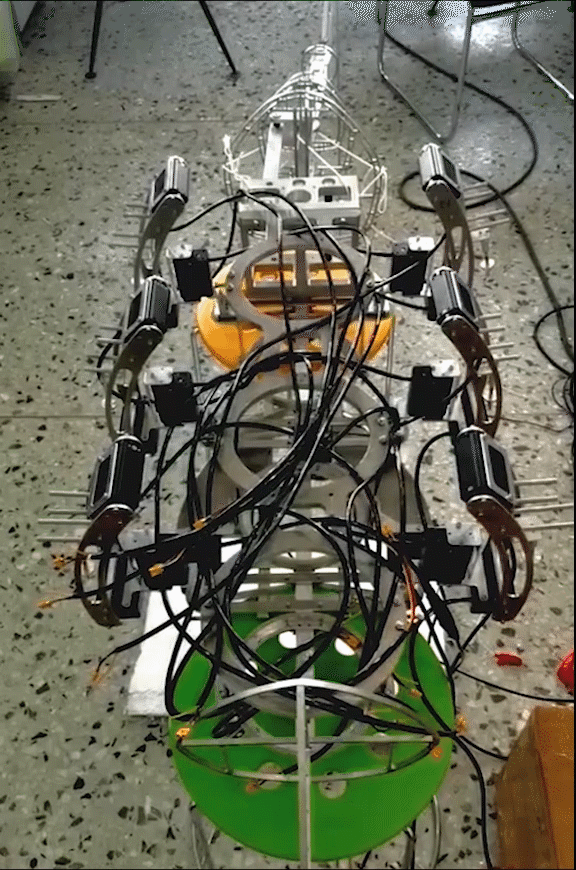 Photo by rawpixel on Unsplash
The robot adopts a bionic propulsion mode to present the shape of a fish as a whole, and on this basis, a six-legged crawling mechanism is added to make it have two movement modes: swimming and crawling, so as to integrate the cruise detection ability of the traditional UUV and the fixed-point operation capability of the ROV.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.