Two-wheeled balancing robot
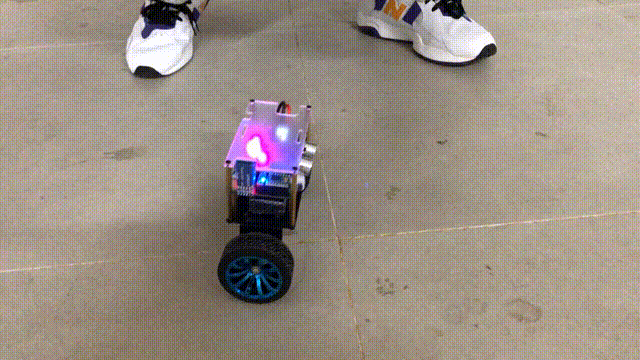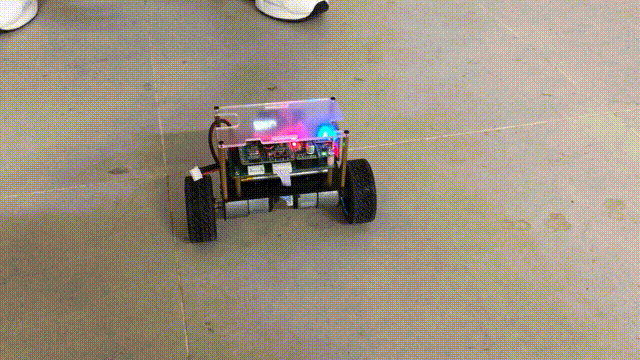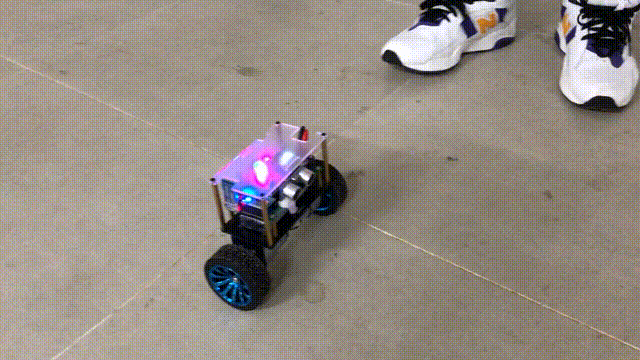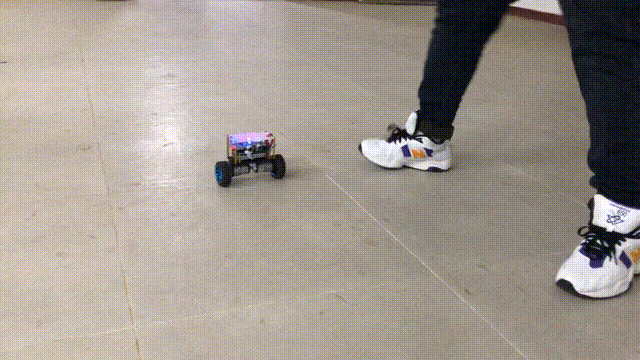 Photo by rawpixel on Unsplash
The internal and external PID dual control loops of the motor, of which the internal control loop: the PID position loop calculated by the AB phase of the Hall encoder; External control loop: the deviation steering loop of the Gyro angle.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.