Compliance control with Franka Emika Panda Robot
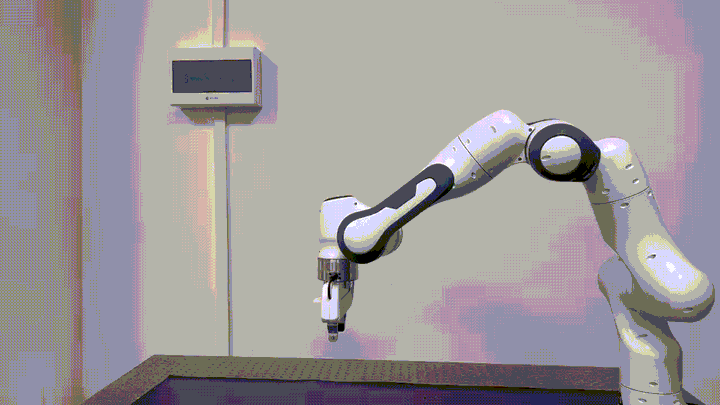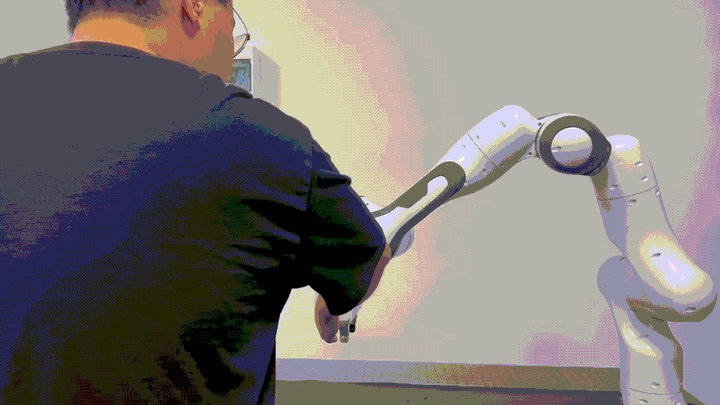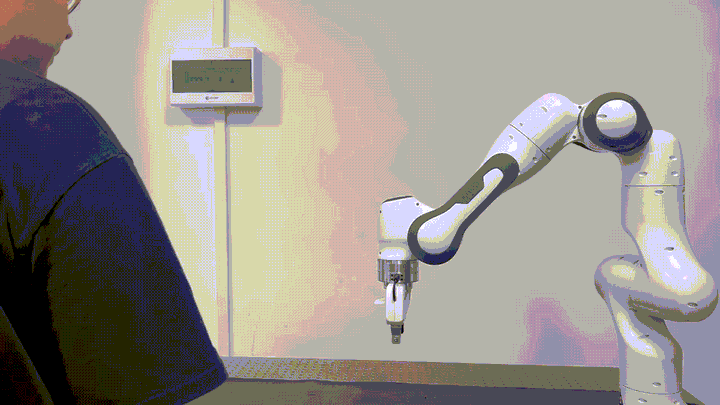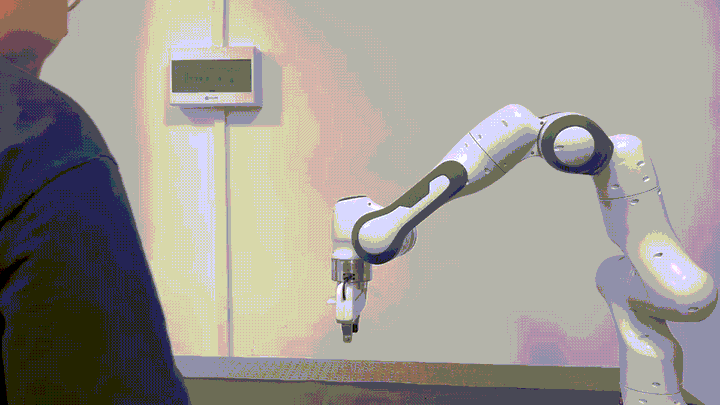 Photo by rawpixel on Unsplash
I used the Franka Emika Panda robot to test screw screwing, with impedance control in the null space and end-effector Cartesian space to complete the task.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.