Wheeled Climbing Robot
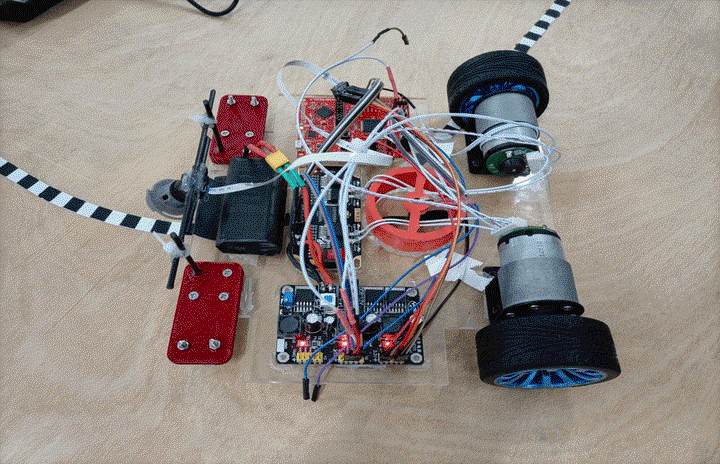 Photo by rawpixel on Unsplash
The robot uses an acrylic plate underbody support structure, and uses a linear CCD camera to collect black squares to follow the track on slpoe; PWM is sent to the MSP430 platform controller through the ADC channel, and the encoder is used to measure the motor speed at all times.
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
My research interests include whole body motion control for humanoid, compliance control and real-world robotic system building.