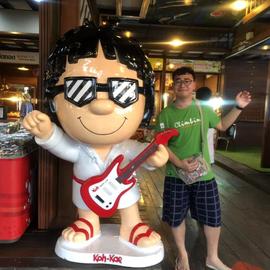
戴梓健
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
Sapienza University of Rome
Biography
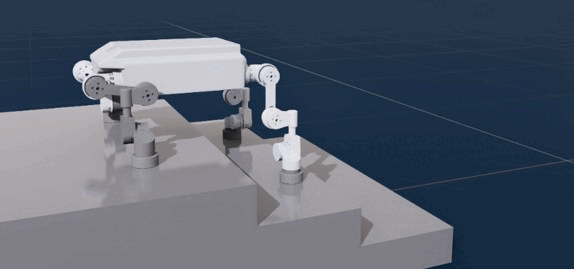
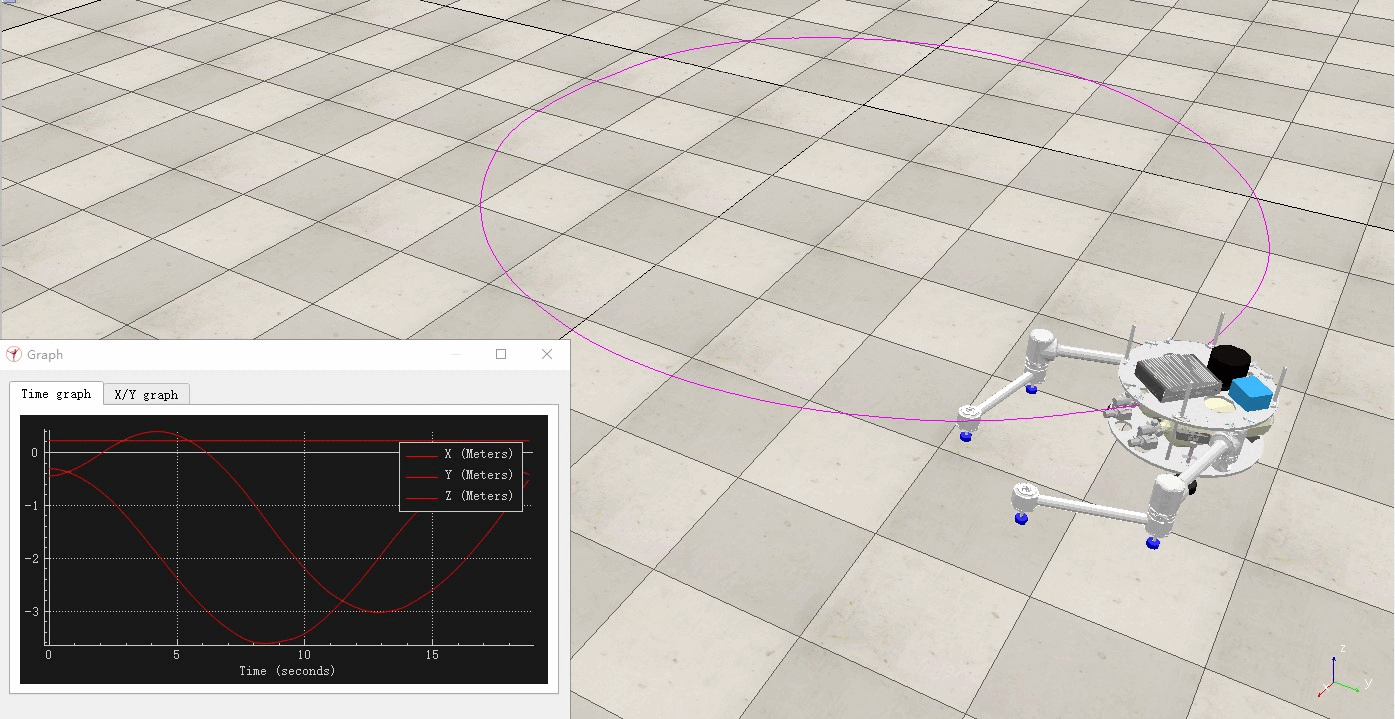
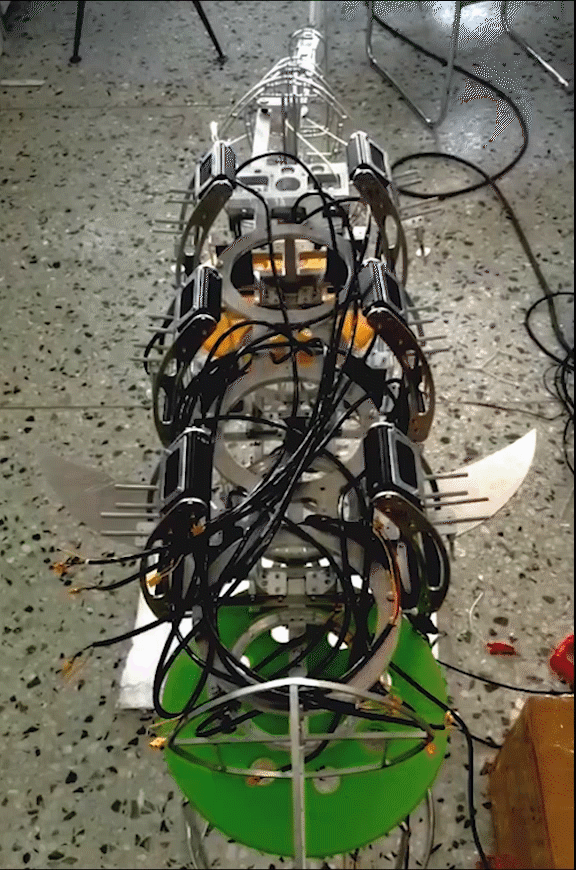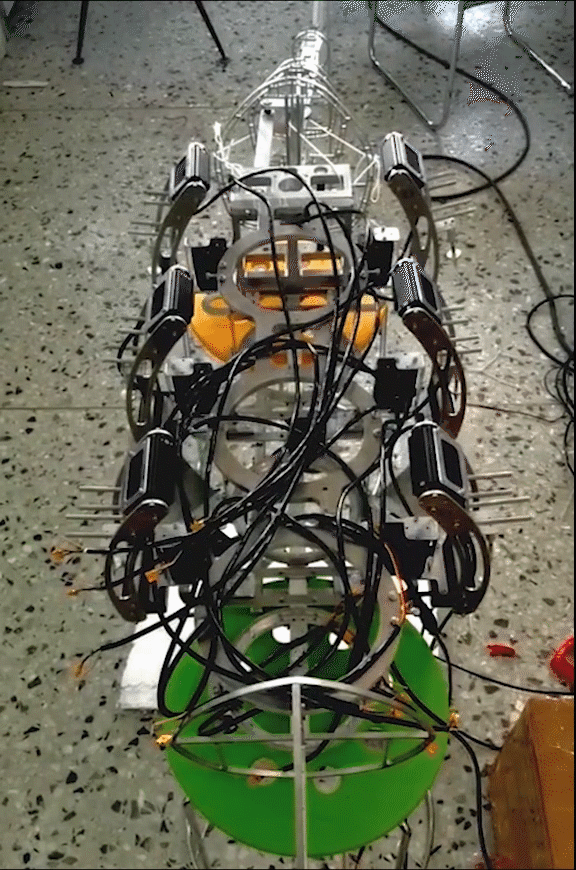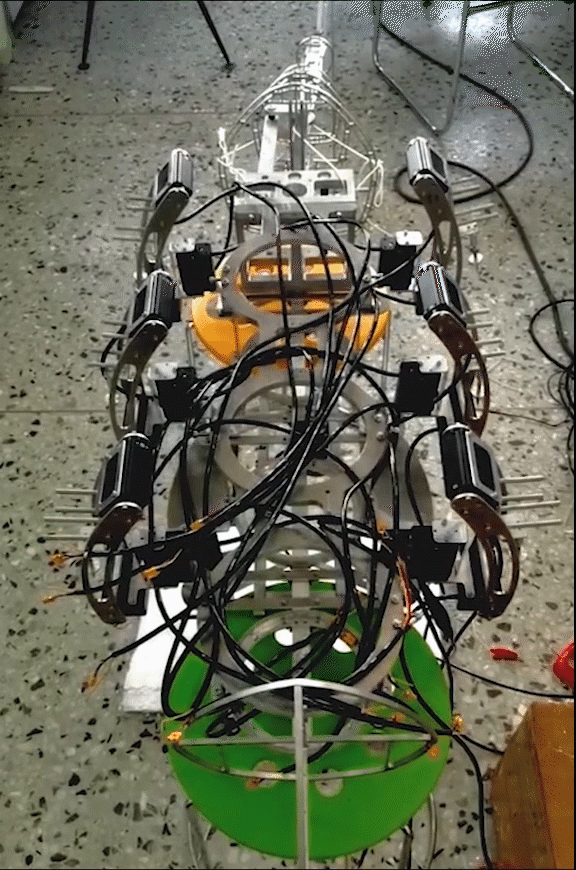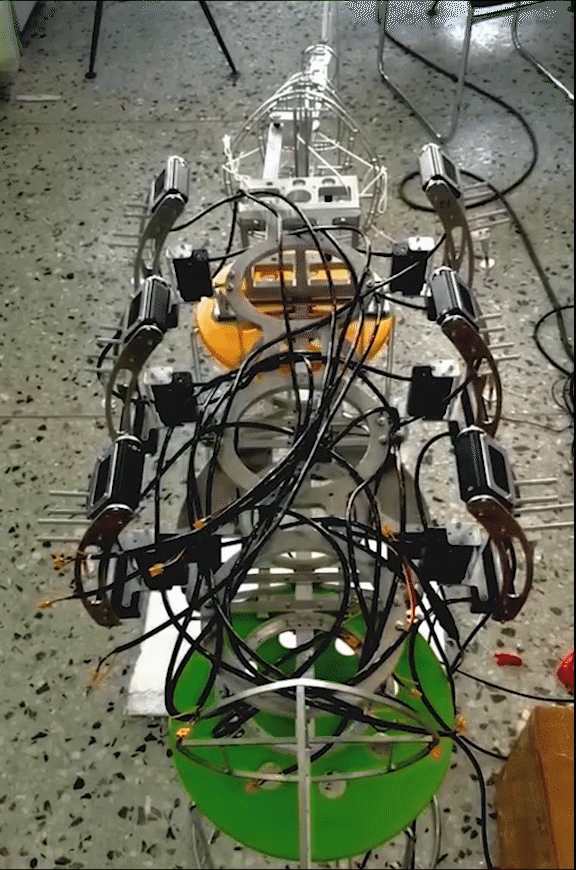
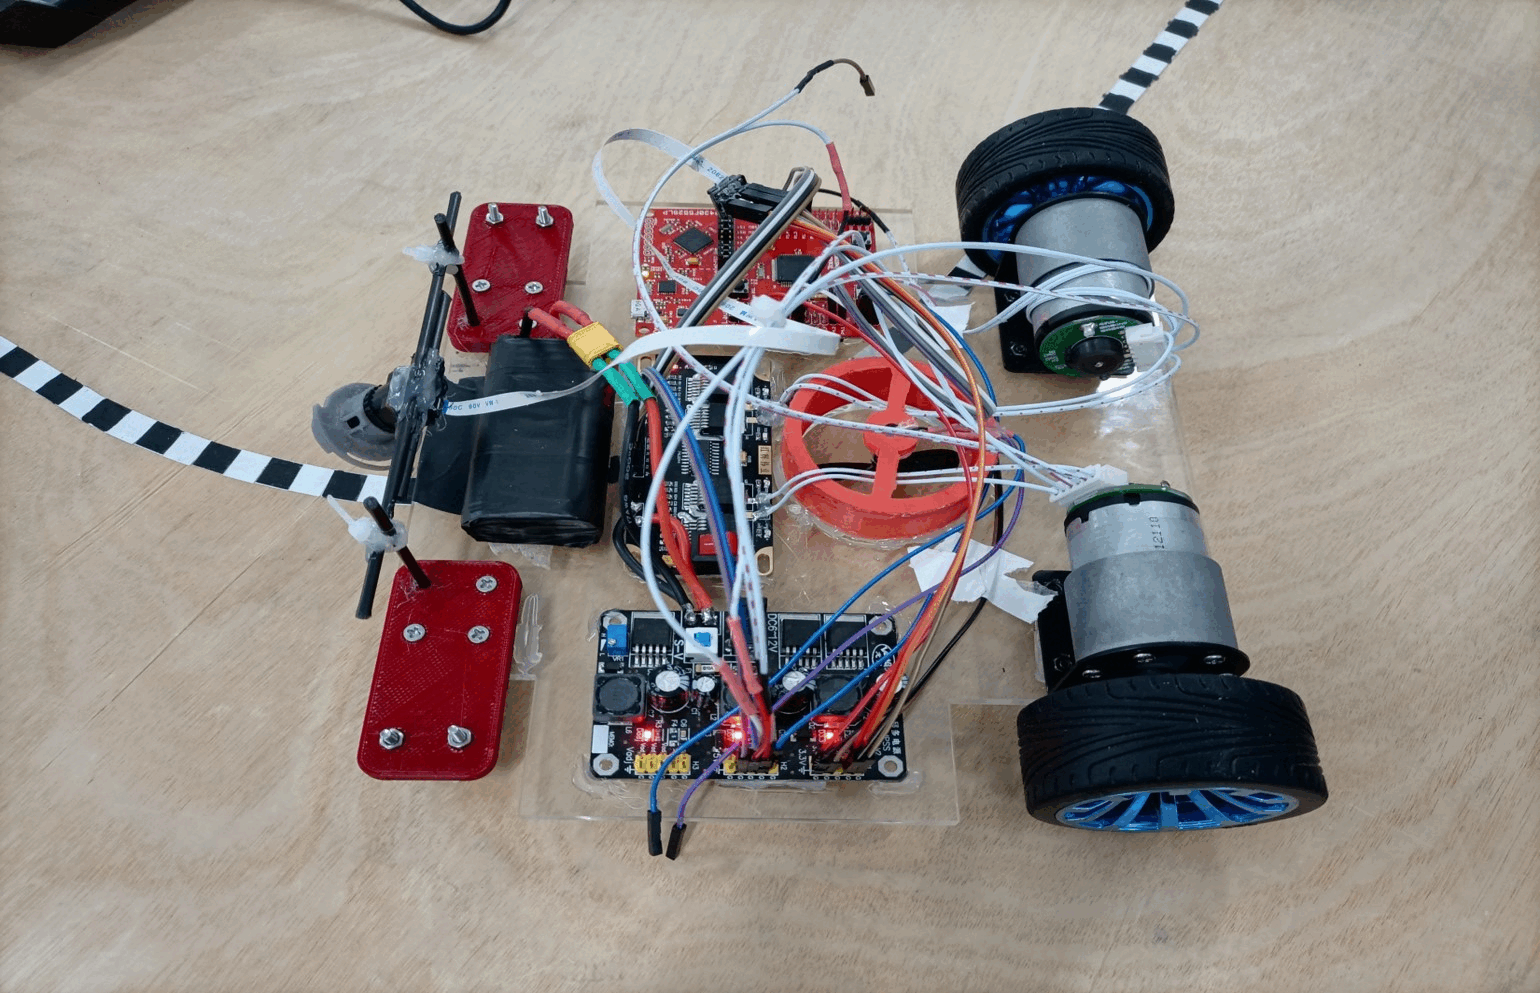
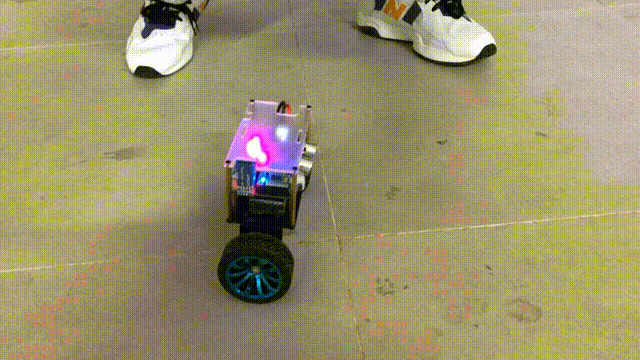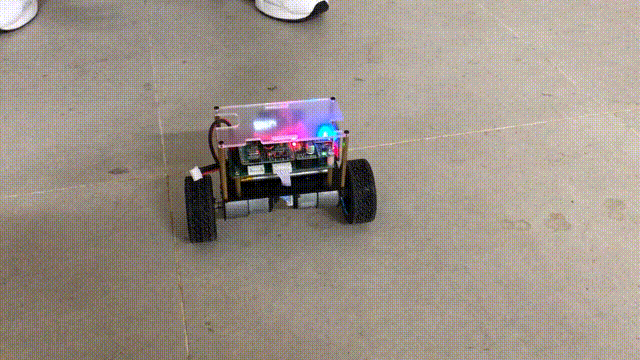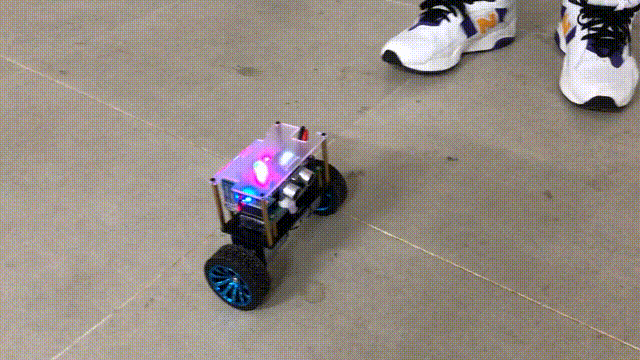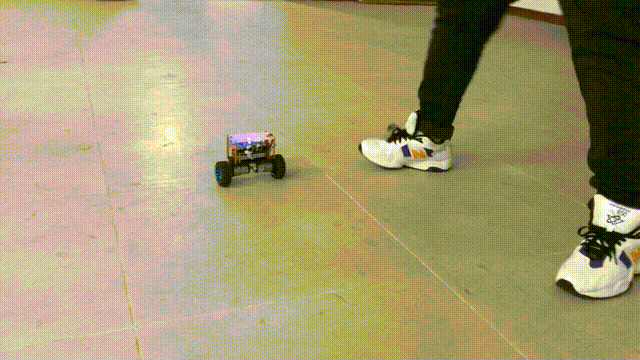
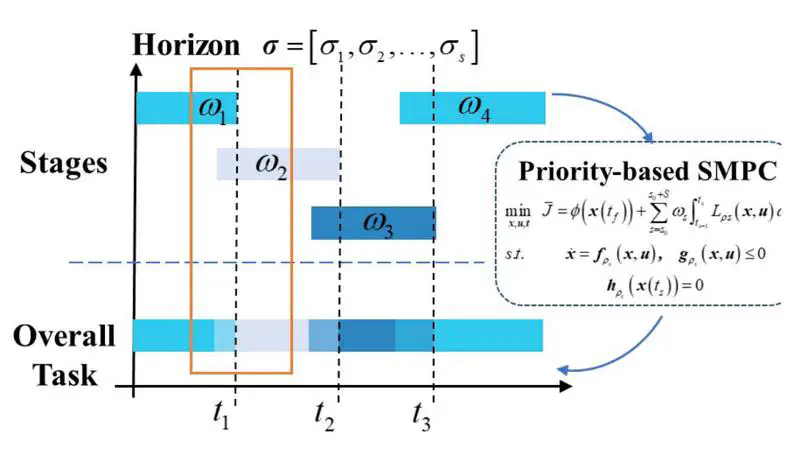
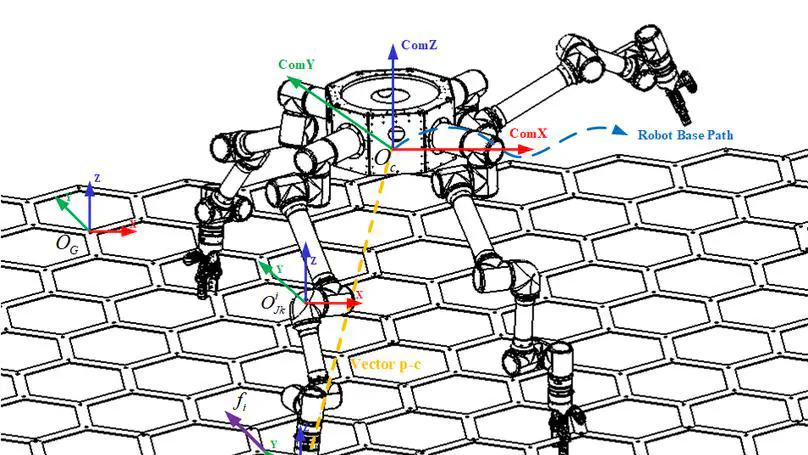
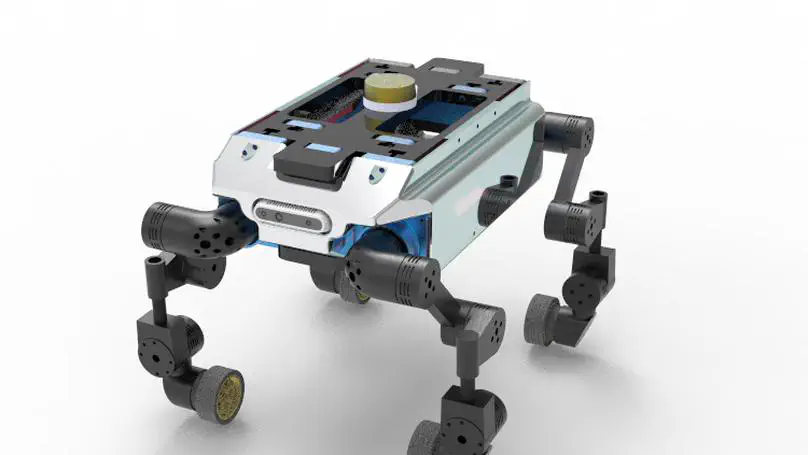
Hi, My name is Zijian Dai. Currently, I am a first-year PhD student majoring in robotics at DIAG Robotics Lab, supervised by Prof. Giuseppe Oriolo (IEEE Fellow). In Mar 2025, I completed my M.Eng in Aerospace at Harbin Institute of Technology, Shenzhen. Before this I completed my B.Eng in Automation at Harbin Engineering University with Prof. Zheping Yan. During my academic career, I have worked on various types of robotics projects, including humanoid, quadruped robots, space robots, robotic arms, underwater robots, wheel robots etc. I am good at embedded development, ROS, and robot joint motion control such as servos/servo motors. My research interests include robot compliant control, whole-body motion control, and real-world robotic system building. In Oct 2024, I finished my internship at Tencent Robotics X Lab. Later, I joined the humanoid project at LimX Dynamics and ended my internship in August 2025. Now, I am joining the Automatic Control, Bioengineering and Operations Research (ABRO) PhD program at Sapienza University of Rome for my PhD degree.
- Compliance Control
- Whole Body Motion Control
- Robot System Building
PhD in Automatic Control, Bioengineering and Operations Research (ABRO)
Sapienza University of Rome (2025~Present)
M.Eng in Aerospace Science and Technology (Robotics)
Harbin Institute of Technology, Shenzhen (2022~2025)
B.Eng in Automation
Harbin Engineering University (2018~2022)
Experience
Projects
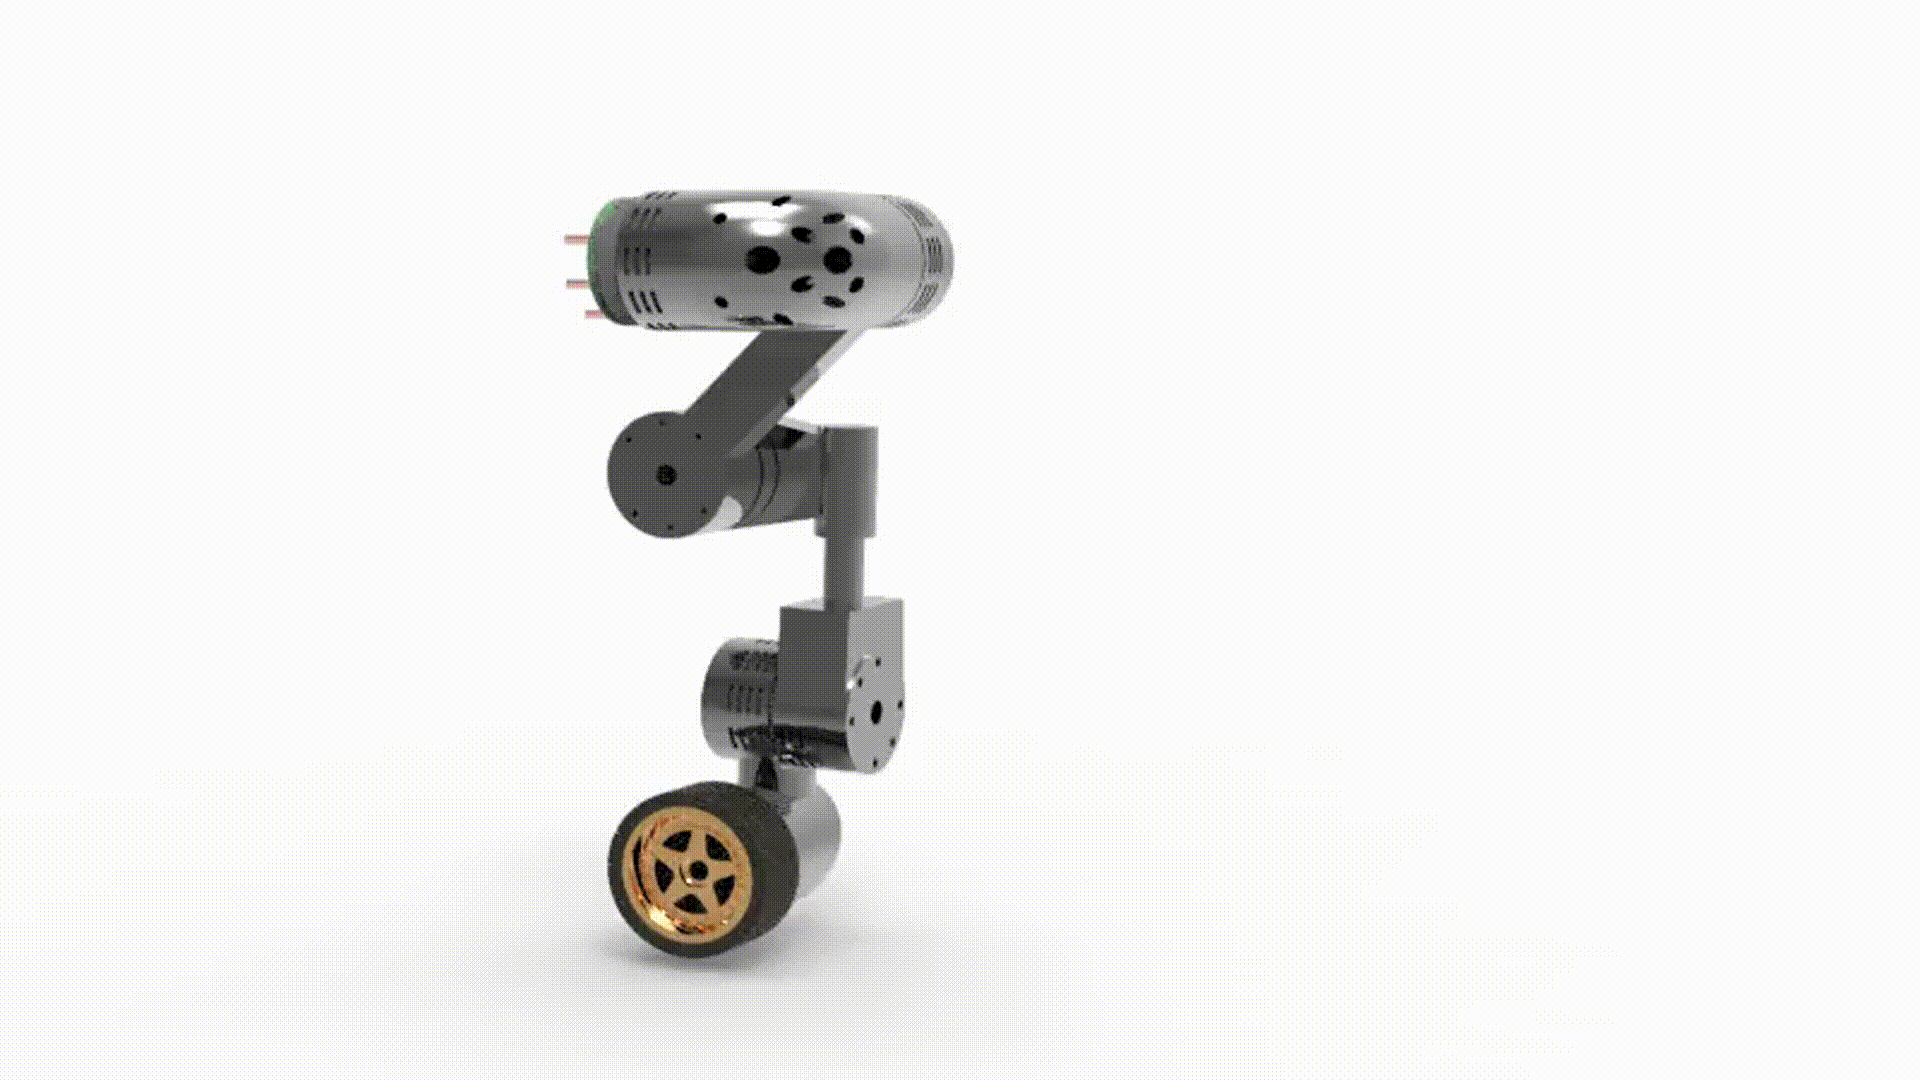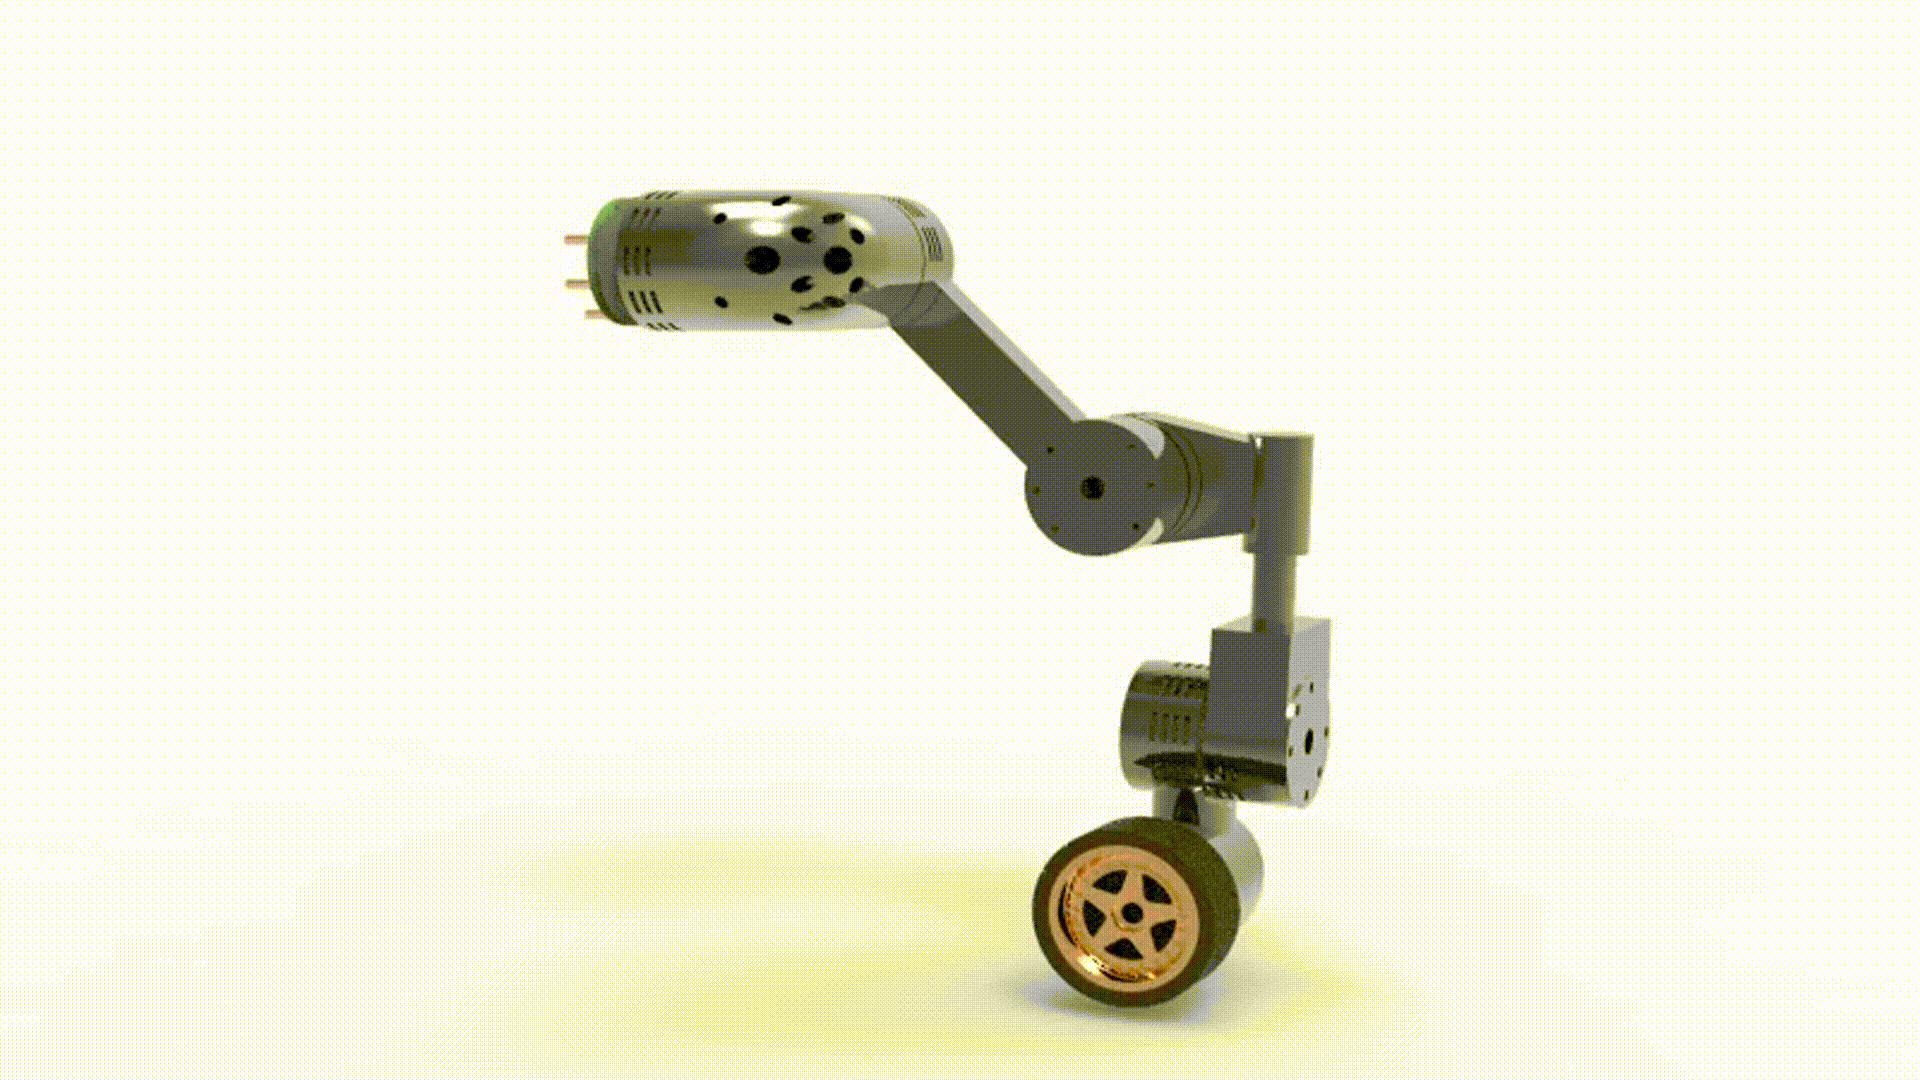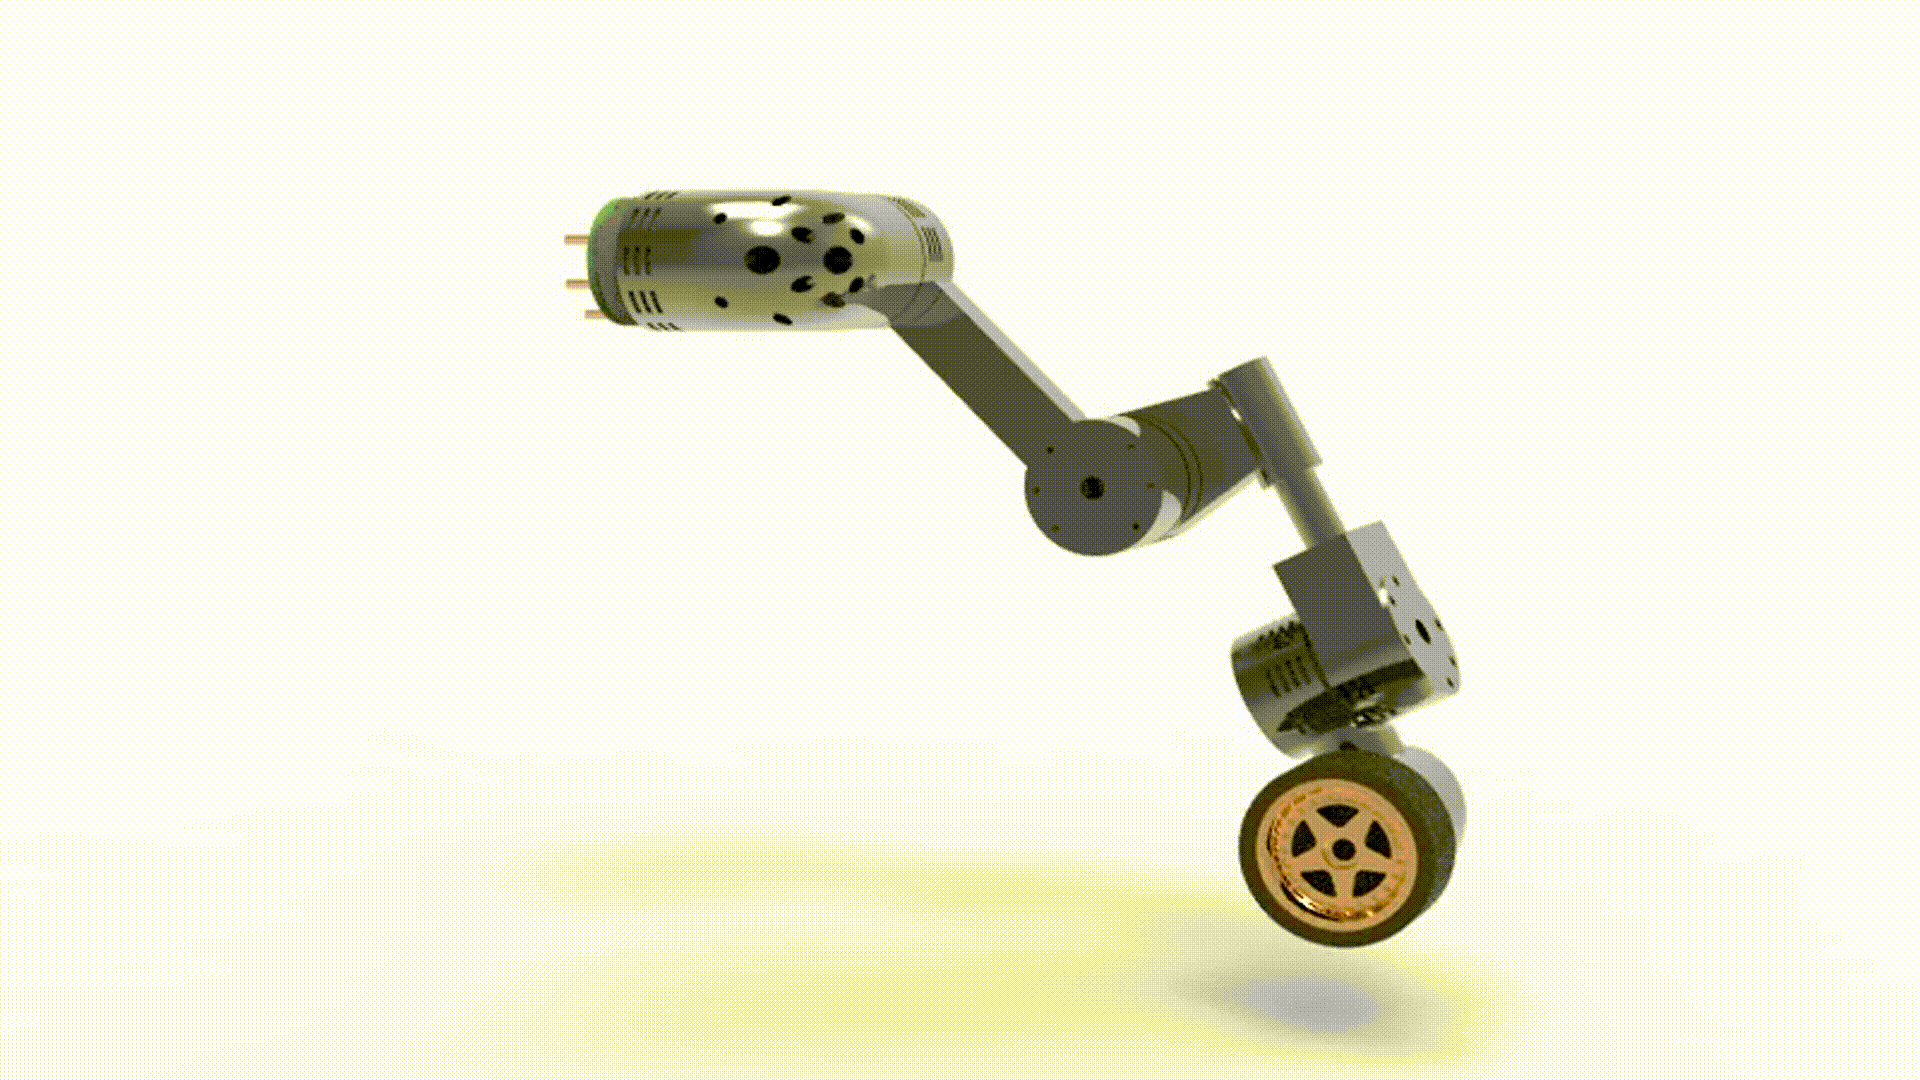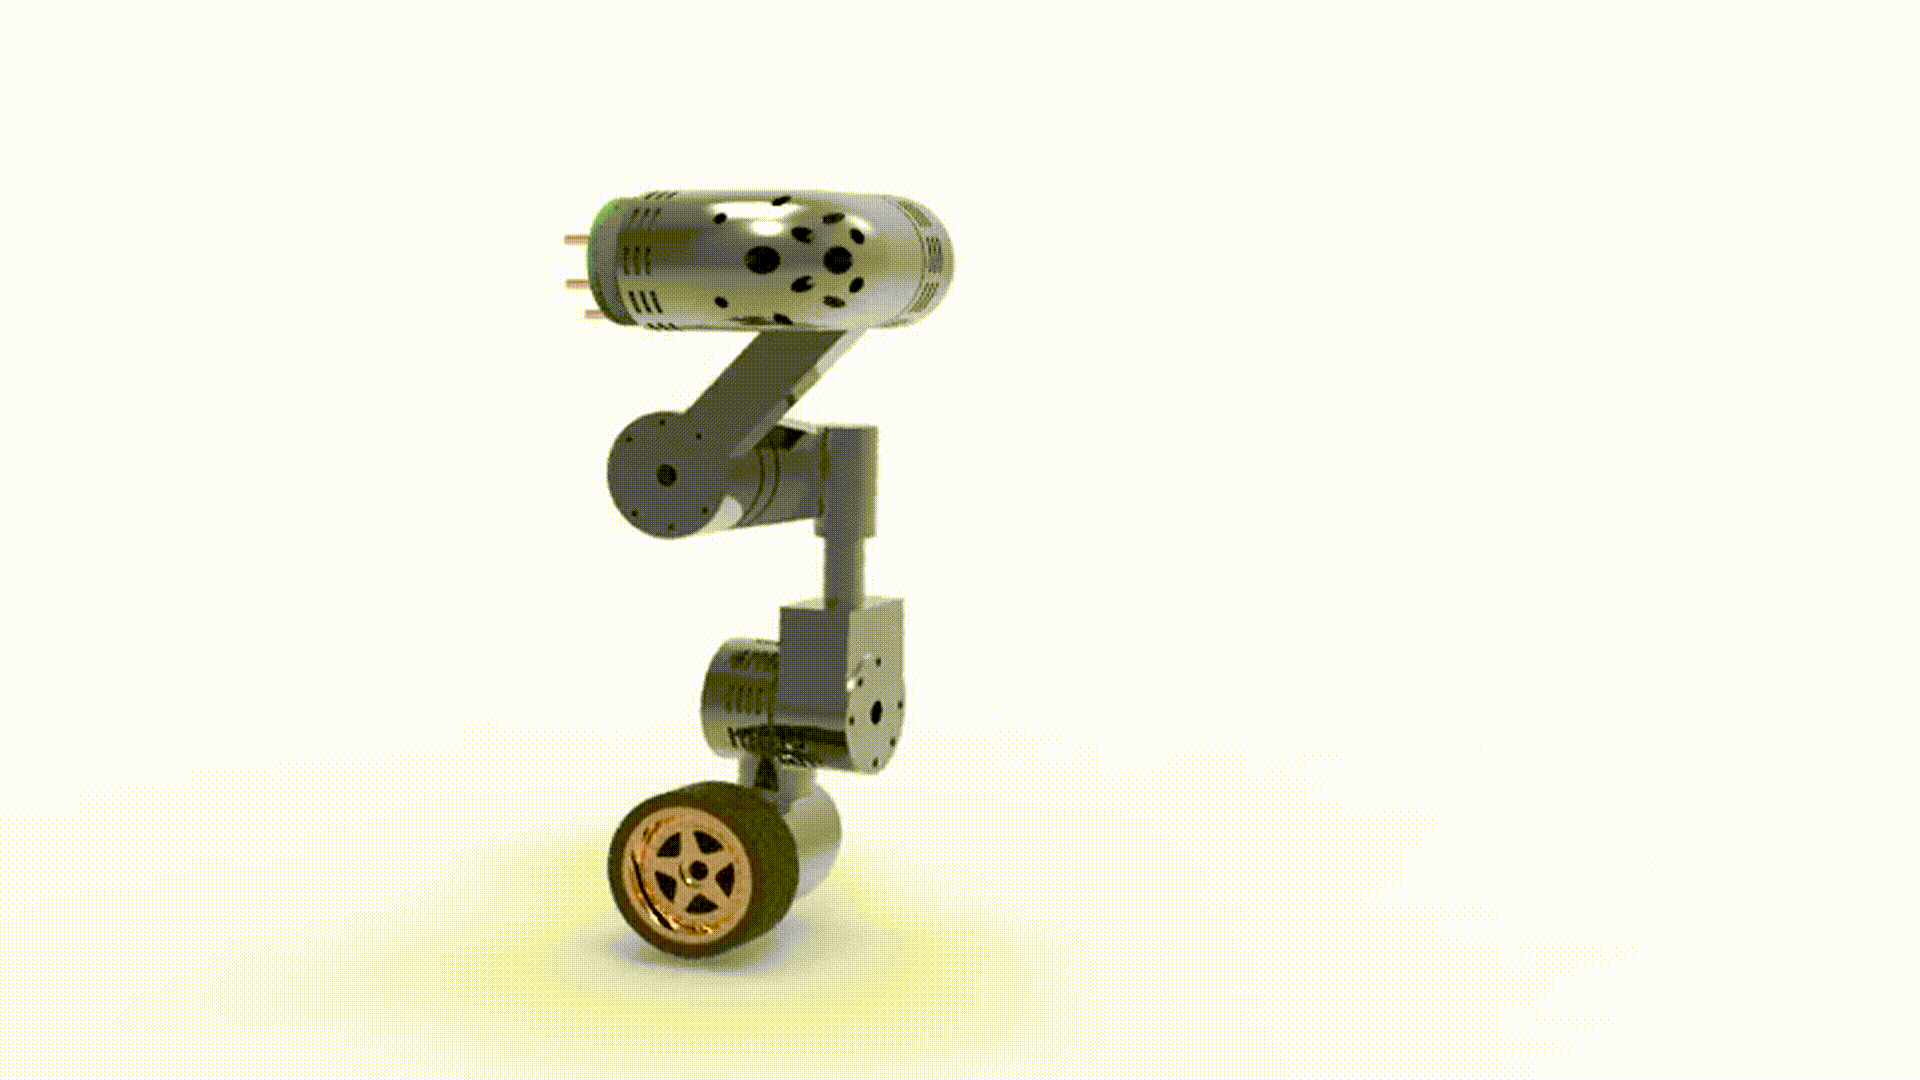
Publications & Patent
Honors
Contact
- daigaulle@gmail.com
- +39 3242668938 | +86 15244668153
- Via Ariosto, Roma, RM 00185
- Via Ariosto, 25, 00185 Roma, Italy